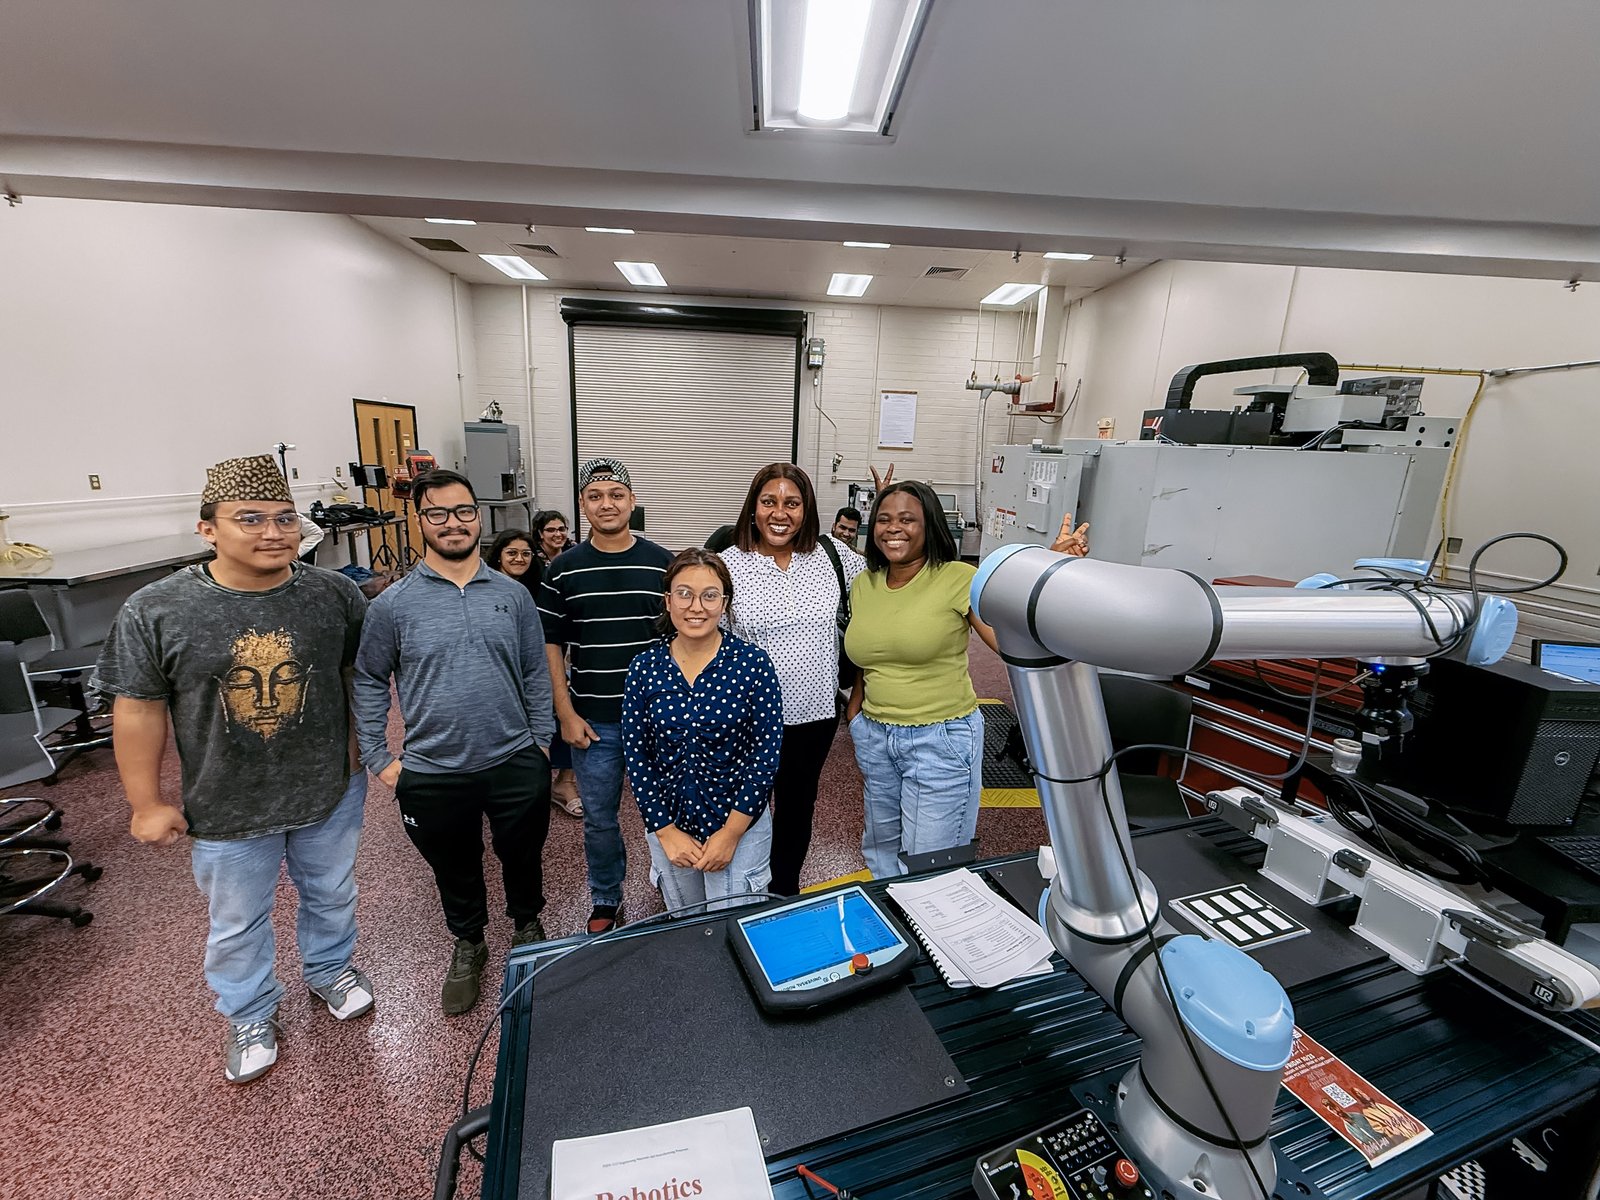
On Monday, October 26, 2026, students in INEN 6301: Advanced Robotics ran their palletizing lab session on the UR10e. The session followed Universal Robots Academy module 9: the whole class built one program with the Palletizing template, then each team copied it and raced the clock.
The challenge
The task combined the conveyor and sensor I/O from the previous race with the new pallet template:
- Six cubes are placed in front of Sensor 1 and Sensor 3, at the two ends of the conveyor.
- The conveyor carries the cubes one at a time to Sensor 2, in the middle of the belt.
- When Sensor 2 detects a cube, the UR10e picks it up and places it in the next nest of a 2 × 3 pallet grid.
- A counter stops the program after the sixth cube, and a timer reports the cycle time from Play to the last placement, conveyor time included.
Teams could raise the robot speeds up to fixed caps, add blend radii, lower the approach and exit heights, remove waypoints they did not need, and time the robot so it was already back over the belt when the next cube arrived. The pallet corners, grid, and belt speed stayed fixed. A dropped cube or a move above a speed cap cost 30 seconds, and a protective stop replaced the score with 240 seconds. For reference, Universal Robots’ own version of this exercise runs about 117 seconds at baseline speeds and about 89 seconds with the speed change alone.
The winners
The winning team stacked all six cubes in 71.794 seconds. Pictured in the front row is Sajita Shrestha. In the back row, from left to right: Prashant Thakuri, Adnan Shafi, Rocktim Shil, Vivian Latona, and Aminat Ayankoya. Five of the six also won the conveyor and sensor I/O race three weeks earlier.
New to the UR10e? Start with the Getting Started with the UR10e Cobot guide. The conveyor and sensors are listed under the UR10e’s accessories on the Lab page.