Getting Started with the UR10e Cobot
Every student who joins a project on the UR10e asks some version of the same question: what do I need to know before I am allowed to touch it? This post is the answer, and it is the same answer for everyone, so it lives here rather than in my outbox.
The order below matters more than the volume. Work through it top to bottom. Steps 1 and 2 are prerequisites for anything hands-on; steps 3 and 4 depend on what your project actually uses, and you can stop after step 2 if your work never touches the camera or the LiDAR safety system.
How to use this
- Start step 1 before you touch the robot. Not because of the paperwork, but because PolyScope makes very little sense until you have seen it explained once, and a confused operator next to a 12.5 kg-payload arm is the exact situation the safety training exists to prevent.
- You can practice on the physical robot while you work through the material. If you need access for that, ask me and I will arrange it — hands-on time on the arm is arranged through me, not self-served. Do not wait until you have “finished” the e-learning — that moment never arrives.
- Read the manual sections you are about to use, not the whole thing. The user manual is a reference, not a course. Operation, safety, and I/O are the sections that pay for themselves immediately.
- Everything below is free, though the UR Academy requires a free account.
1. Universal Robots fundamentals
Start here regardless of what your project is about. This is the required first step.
| Resource | What it is | Why bother |
|---|---|---|
| UR e-Series e-Learning | Official module series from UR Academy | The baseline for everything else. Register a free account to unlock all modules. |
| UR Lab Manual (PDF) | Our lab session manual for INEN 5301 / 6301, 37 activities across Modules 5–11 | The same material done on our arm: getting started, motion, pick and place, programming, palletizing, features/planes, and safety settings |
The modules cover the robot hardware, the PolyScope interface, basic program structure, and safety. By the end you should be able to jog the arm, build a simple waypoint program, and explain what a safety configuration limit is and why you cannot change it casually.
The lab manual is the hands-on half of this step. Its activities are adapted from the UR Academy student modules 5–11, so work through each one at the robot after the matching e-learning module. A printed copy stays at the robot cell.
2. The UR10e user manual
Read this after the e-learning, or in parallel with it. The modules teach you the platform; the manual tells you about the specific arm in our lab.
| Resource | What it is | Why bother |
|---|---|---|
| UR10e User Manual (PDF) | The full manual for our model | Model-specific limits, safety functions, and electrical interfaces |
Focus on the sections covering operation, safety, and I/O. The I/O chapter in particular is the one people skip and then lose an afternoon to, because every gripper, sensor, and conveyor handshake on our setup eventually comes back to a tool or controller I/O pin.
3. Camera and vision
Relevant if your project involves the wrist camera — object detection, part location, or any vision-guided pick.
| Resource | What it is | Why bother |
|---|---|---|
| Wrist Camera Advanced Parameters | Robotiq e-learning course | Exposure, focus, and detection parameters — the settings that decide whether your snapshot works |
| Wrist Camera Instruction Manual (PDF) | Robotiq reference manual | Mounting, calibration, and the camera node’s behavior in a program |
Take the course first and the manual second. Most early vision failures are not algorithmic — they are lighting, exposure, or a teach-object step done under conditions that no longer hold.
Specs and links for the camera itself: Wrist Camera under Accessories below.
4. LiDAR and human–robot collaboration
Relevant if your project involves shared workspace, speed-and-separation monitoring, or any question about what the robot does when a person walks up to it.
| Resource | What it is | Why bother |
|---|---|---|
| UR Marketplace: SICK sBot Stop | Product page for the nanoScan3 Core safety package on our cell | What the hardware actually provides, and where it sits in the safety chain |
| LiDAR-based safety in HRC | Research paper, Sensors 23(9):4305 | The research framing: how zone monitoring translates into collaborative operation |
Read the product page for the mechanism and the paper for the reasoning. The distinction that matters here is between a safety function that is certified and a perception feature that is merely useful — collaborative operation depends entirely on which one you are relying on.
Specs for our two scanners: nanoScan3 Core Safety Laser Scanners under Accessories below.
Accessories on our UR10e
These are mounted on or wired to our arm. Each entry lists the maker’s product page, manuals, and training material where they exist. For the Robotiq accessories, manuals, software (URCaps), and 3D models are all also collected on the Robotiq support site.
WINGMAN Cobot Tool Changer
TripleA Robotics
A plug-and-play mechanical tool changer that lets the cobot switch end-effectors in seconds, automatically or by hand. Automatic changes need no power or compressed air: the arm's own motion through the tool holder locks and releases each tool. Optional pass-through modules carry electrical signals and air or vacuum to the mounted end-effector.
- Manual or automatic tool change
- Mechanical locking; no power or air needed to change tools
- Tool holder supports end-effectors up to 5 kg
- Optional electrical (M8/M12) and pneumatic/vacuum pass-through
| Resource | What it is |
|---|---|
| Product page | TripleA's product overview, kits, and datasheets |
| UR Marketplace | UR+ listing with Universal Robots compatibility details |
| User guide (PDF) | Installation, manual and automatic tool changes, and safety requirements |
| Overview video | The tool changer in use, shown on a Doosan arm |
| Demo on UR | Automatic tool changes on a Universal Robots arm |
Screwdriving Solution
Robotiq
A complete robotic screwdriving package. The SF-300 screw feeder presents screws one at a time, and the SD-100 screwdriver picks each one up by vacuum and drives it at a set torque. Programming runs on the teach pendant through the Robotiq_Screwdriving URCap, which adds force sensing to the drive.
- Torque: 0.5–4 Nm
- Screws: M2.5–M5, 4–25 mm long, any material
- Vacuum air supply: 100 psi
- URCap: Robotiq_Screwdriving (PolyScope 5.9.4 or later on e-Series)
| Resource | What it is |
|---|---|
| UR Marketplace | Product listing with specs and what is in the box |
| Instruction manual (PDF) | Full reference: installation, URCap, operation, and calibration |
| Quick start guide: screwdriver (PDF) | Mounting and wiring the SD-100 screwdriver |
| Quick start guide: screw feeder (PDF) | Setting up the SF-300 screw feeder |
| Vacuum sleeve selection chart (PDF) | Which vacuum sleeve to use for each screw size |
| Product sheet (PDF) | Short summary of specs and features |
| Declaration of incorporation (PDF) | EC declaration for the SD-100: standards and certificates |
| CAD: screwdriver (ZIP) | 3D model of the screwdriver for cell layout |
| CAD: screw feeder (STEP) | 3D model of the screw feeder |
| e-Learning course | Robotiq's free step-by-step installation and programming course |
EPick Vacuum Gripper
Robotiq
An electric vacuum gripper with a built-in pump, so it runs without compressed air. It handles flat or smooth parts that fingers grip poorly, such as sheet metal, glass, boxes, and plastic panels.
- Built-in electric vacuum pump; no compressed air
- Single-, dual-, or quad-cup configurations
| Resource | What it is |
|---|---|
| UR Marketplace | Product listing and specs |
| Instruction manual (PDF) | Installation, control, and maintenance on e-Series robots |
| Quick start guide (PDF) | Mounting and wiring the EPick on an e-Series UR arm |
| Robotiq User Interface manual (PDF) | Using the Robotiq user interface to test and control the gripper |
| TCP and center of mass table (PDF) | TCP offset and mass values to enter in the robot payload setup |
| Connector assembly guide (PDF) | Assembling the vacuum gripper connectors |
| Declaration of incorporation (PDF) | EC declaration for the EPick: standards and certificates |
| e-Learning course | Robotiq's Vacuum Grippers course (EPick and AirPick) |
| Installation video | Mounting and connecting the EPick on a UR arm |
2F-85 Adaptive Gripper
Robotiq
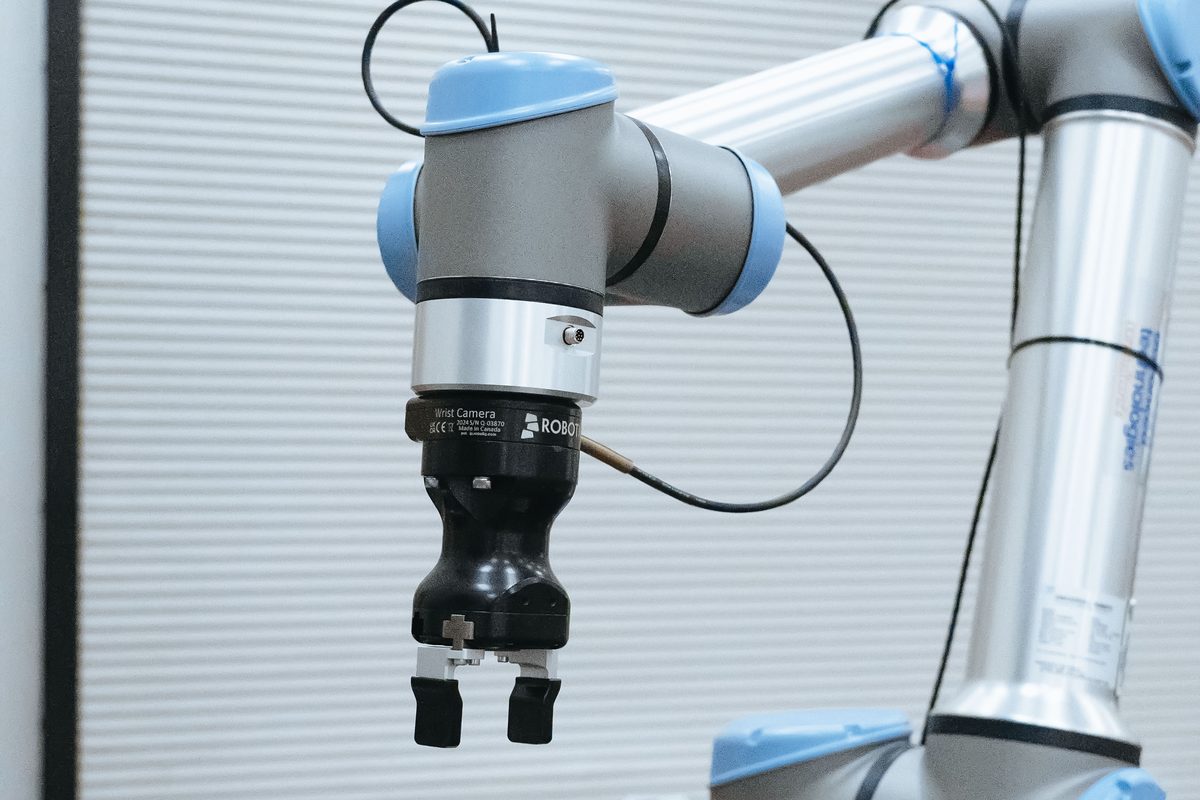
A two-finger electric gripper with an 85 mm stroke. The fingers can pinch a part in parallel or wrap around it, and the gripper reports object detection back to the robot program. It is the gripper students use in the pick-and-place exercises.
- Stroke: 85 mm
- Grip force: 20–235 N
- Parallel and encompassing grip; object detection
| Resource | What it is |
|---|---|
| UR Marketplace | Product listing and specs |
| Instruction manual (PDF) | Installation, control, and specs on e-Series robots (covers 2F-85 and 2F-140) |
| Quick start guide (PDF) | Mounting and wiring the 2F-85 on an e-Series UR arm |
| Robotiq User Interface manual (PDF) | Using the Robotiq user interface to test and control the gripper |
| TCP and center of mass table (PDF) | TCP offset and mass values to enter in the robot payload setup |
| Product sheet (PDF) | Short summary of specs and features for the adaptive grippers |
| Declaration of incorporation (PDF) | EC declaration for the 2F grippers: standards and certificates |
| e-Learning course | Robotiq's Adaptive Grippers course: install, program, set payload and TCP |
Wrist Camera
Robotiq
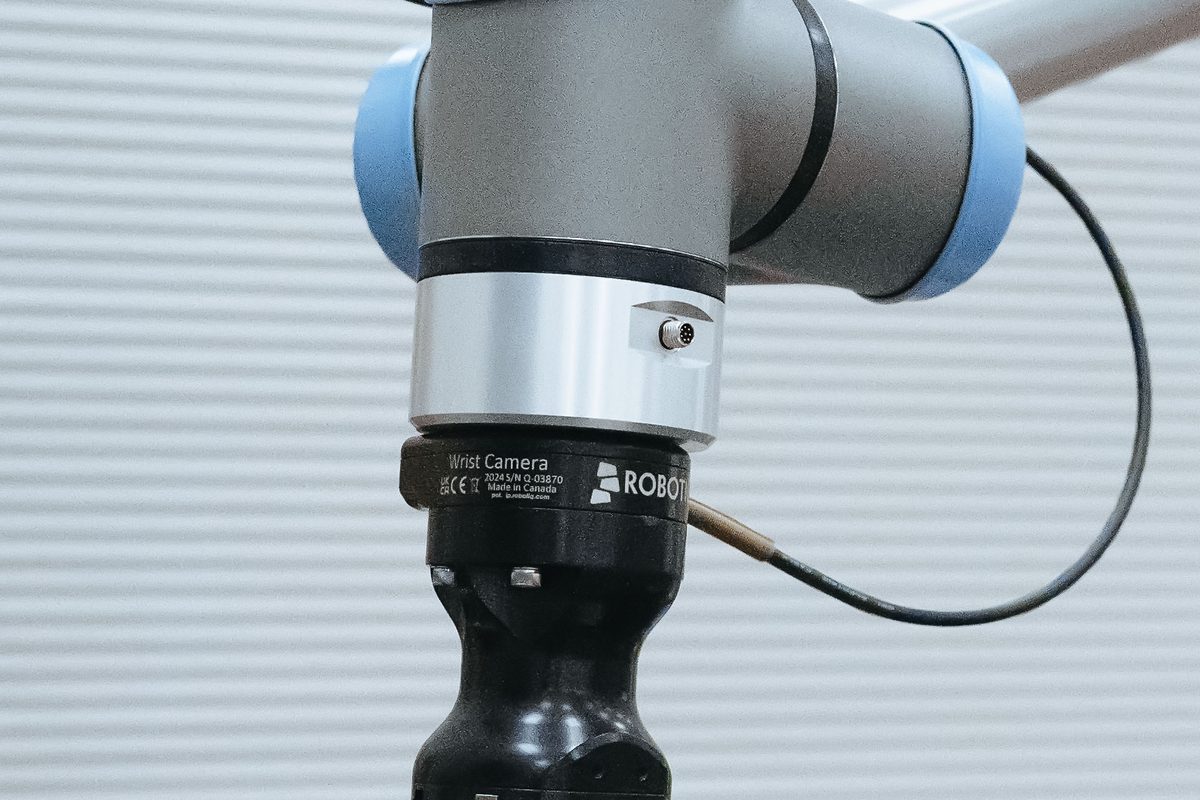
A camera mounted between the robot's tool flange and the gripper. From the teach pendant, students teach it a part, and it then locates that part on the work surface and passes the position to the robot program, with no separate vision PC.
| Resource | What it is |
|---|---|
| UR Marketplace | Product listing and specs |
| Instruction manual (PDF) | Mounting, calibration, and the camera locate node |
| Quick start guide (PDF) | Mounting and wiring the camera on an e-Series UR arm |
| Calibration board, UR5 and UR10 (PDF) | Printable board for calibrating the camera on the work surface |
| TCP and center of mass table (PDF) | TCP offset and mass values to enter in the robot payload setup |
| Declaration of conformity (PDF) | EU declaration for the camera: standards and certificates |
| CAD: 3D model (STEP) | 3D model of the camera for cell layout |
| 2D drawing (PDF) | Dimensioned drawing of the camera |
| e-Learning course | Robotiq's Wrist Camera course, including advanced detection parameters |
Academy Hardware Set
Universal Robots
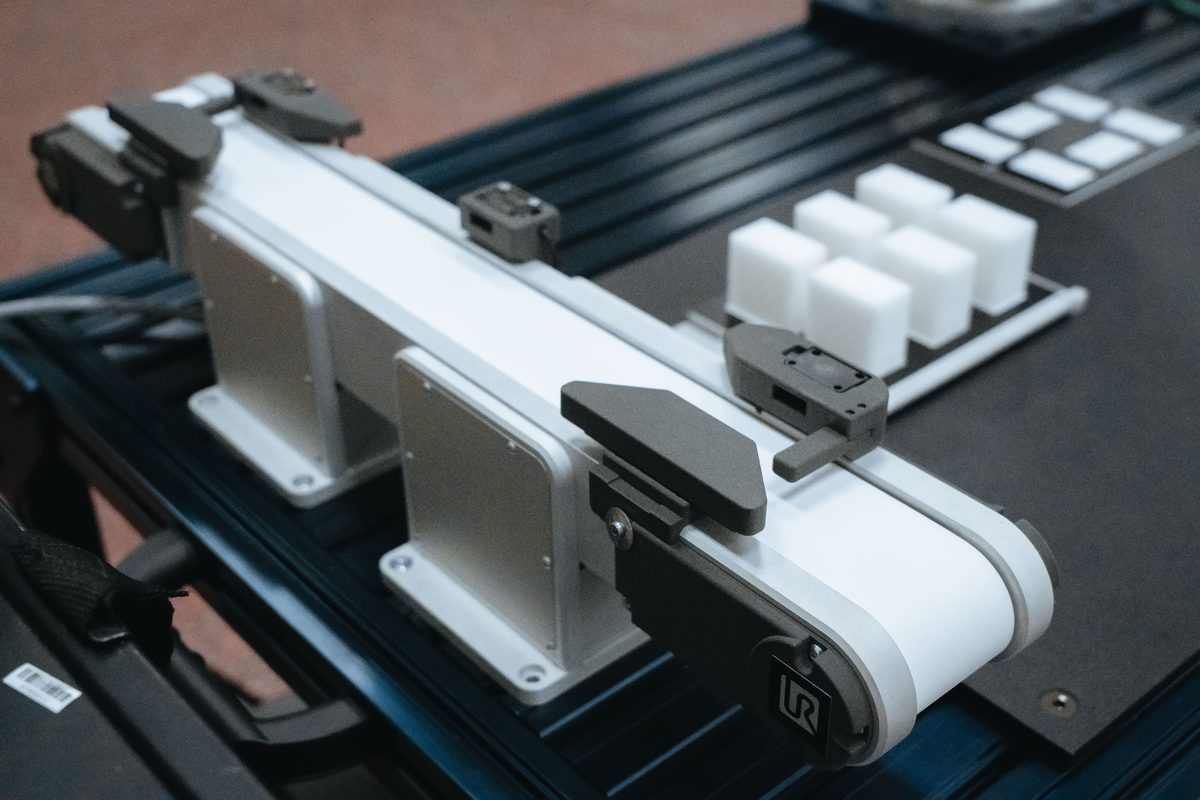
UR's training kit for classrooms and labs, built to work with any UR cobot. Ours is a beech multiplex panel with conveyor belts, an I/O simulator, and presence sensors that detect when a part is in position. Students use it to practice pick and place, palletizing, dispensing, force control, and multi-end-effector tasks, and to wire and program the peripherals a real cell depends on.
- Beech multiplex panel with conveyor belts and an I/O simulator
- Presence sensors wired to the robot's digital inputs
- Simulates pick and place, palletizing, dispensing, force control, and multi-end-effector work
| Resource | What it is |
|---|---|
| UR Marketplace | Overview and features of the set |
| Conveyor tracking setup video | Setting up conveyor tracking on a UR10e |
| Conveyor tracking guide | UR's step-by-step article on the conveyor tracking wizard |
I/O and Simulated Safety Scanner Box
Universal Robots
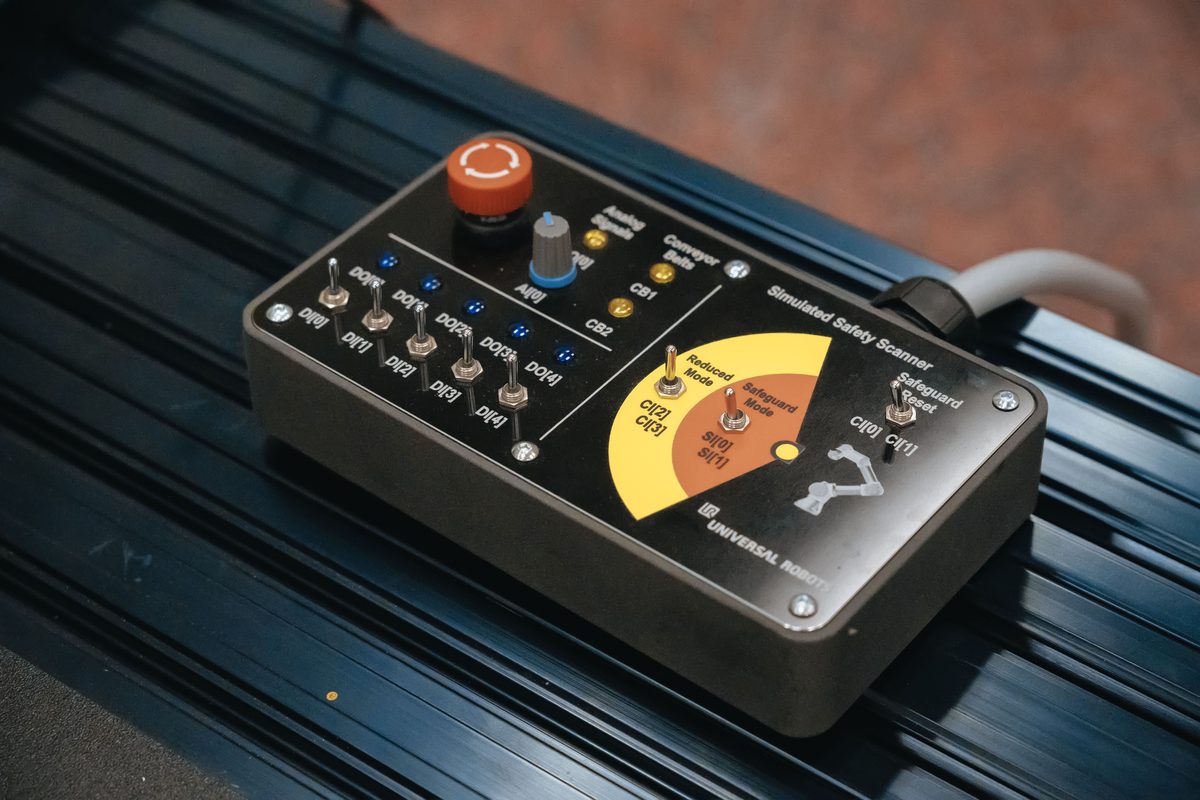
A desktop box wired to the controller's I/O so students can trigger inputs and watch outputs without building a cell. Toggle switches drive the digital inputs, lights show the digital outputs, a knob feeds an analog input, and two lights are labeled for the conveyor belts. Its simulated safety scanner section switches the robot into Reduced Mode or Safeguard Mode and resets the safeguard stop, so safety I/O can be configured and tested without a real scanner. An emergency stop button sits on top.
- Digital inputs DI[0]–DI[4] on toggle switches; outputs DO[0]–DO[4] on lights
- Analog input AI[0] on a knob; conveyor lights CB1 and CB2
- Reduced Mode (CI[2]/CI[3]), Safeguard Mode (SI[0]/SI[1]), Safeguard Reset (CI[0]/CI[1])
- Emergency stop button
nanoScan3 Core Safety Laser Scanners
SICK
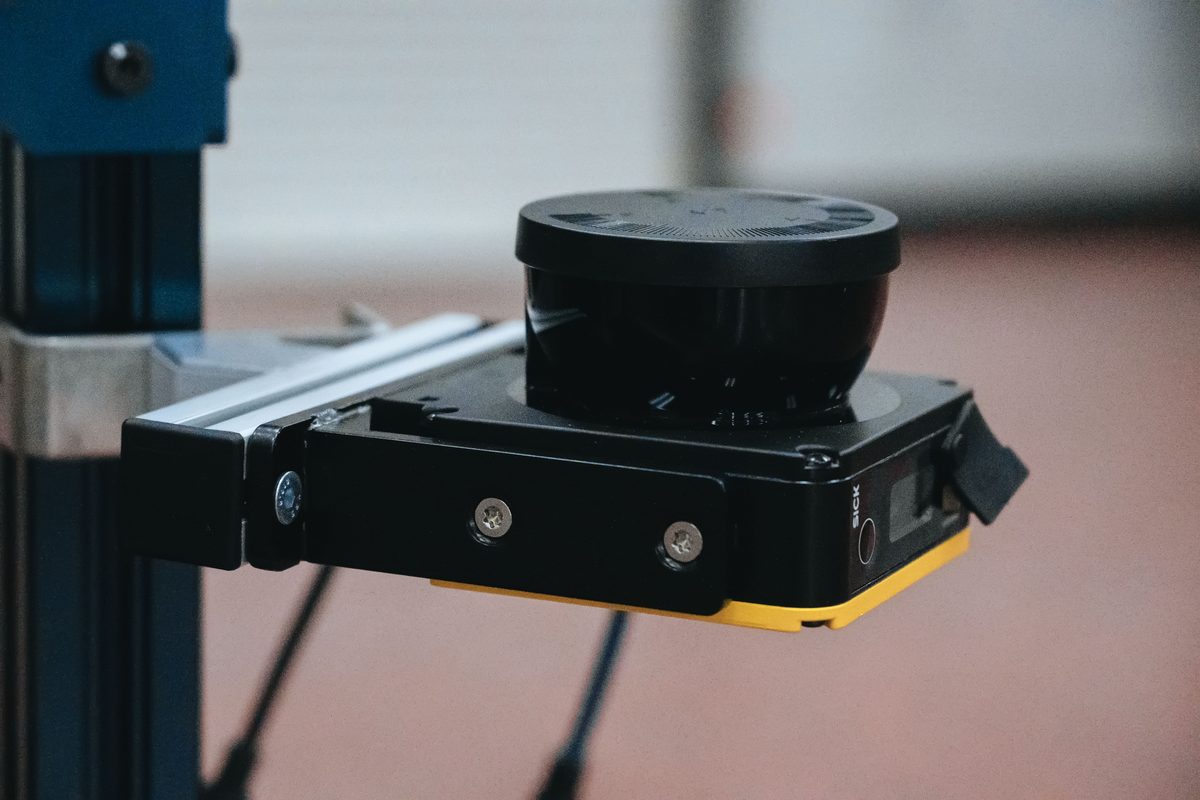
Two compact safety laser scanners watch the floor around the cell. Each monitors a protective field and a warning field, and the robot stops when a person steps into the protective field. The fields are set up on the UR teach pendant with SICK's nanoScan3 Tool URCap.
- Quantity: 2
- Protective field range: 3 m
- Scanning angle: 275°
| Resource | What it is |
|---|---|
| Product page | SICK's nanoScan3 family page with specs and variants |
| UR Marketplace (sBot Stop) | The SICK package on our cell: nanoScan3 Core plus the URCap |
| Operating instructions (PDF) | SICK's full scanner manual: mounting, protective fields, and safety functions |
| sBot operating instructions (PDF) | Setting up the sBot Stop and sBot Speed packages on a UR robot |
| URCap instructions (PDF) | Configuring the scanner fields from the UR teach pendant |
| sBot Stop/Speed video | SICK's walkthrough of configuring the scanners from the URCap |
| UR Forum: nanoScan3 setup | Why the scanner keeps triggering safeguard stops while you program, and the mode-switch fix |
What comes next
Once you have worked through the steps relevant to your project, come see me and we will scope a first task on the actual hardware. Bring a specific thing you want the arm to do; “learn the robot” is not a task and you have already done it by this point.