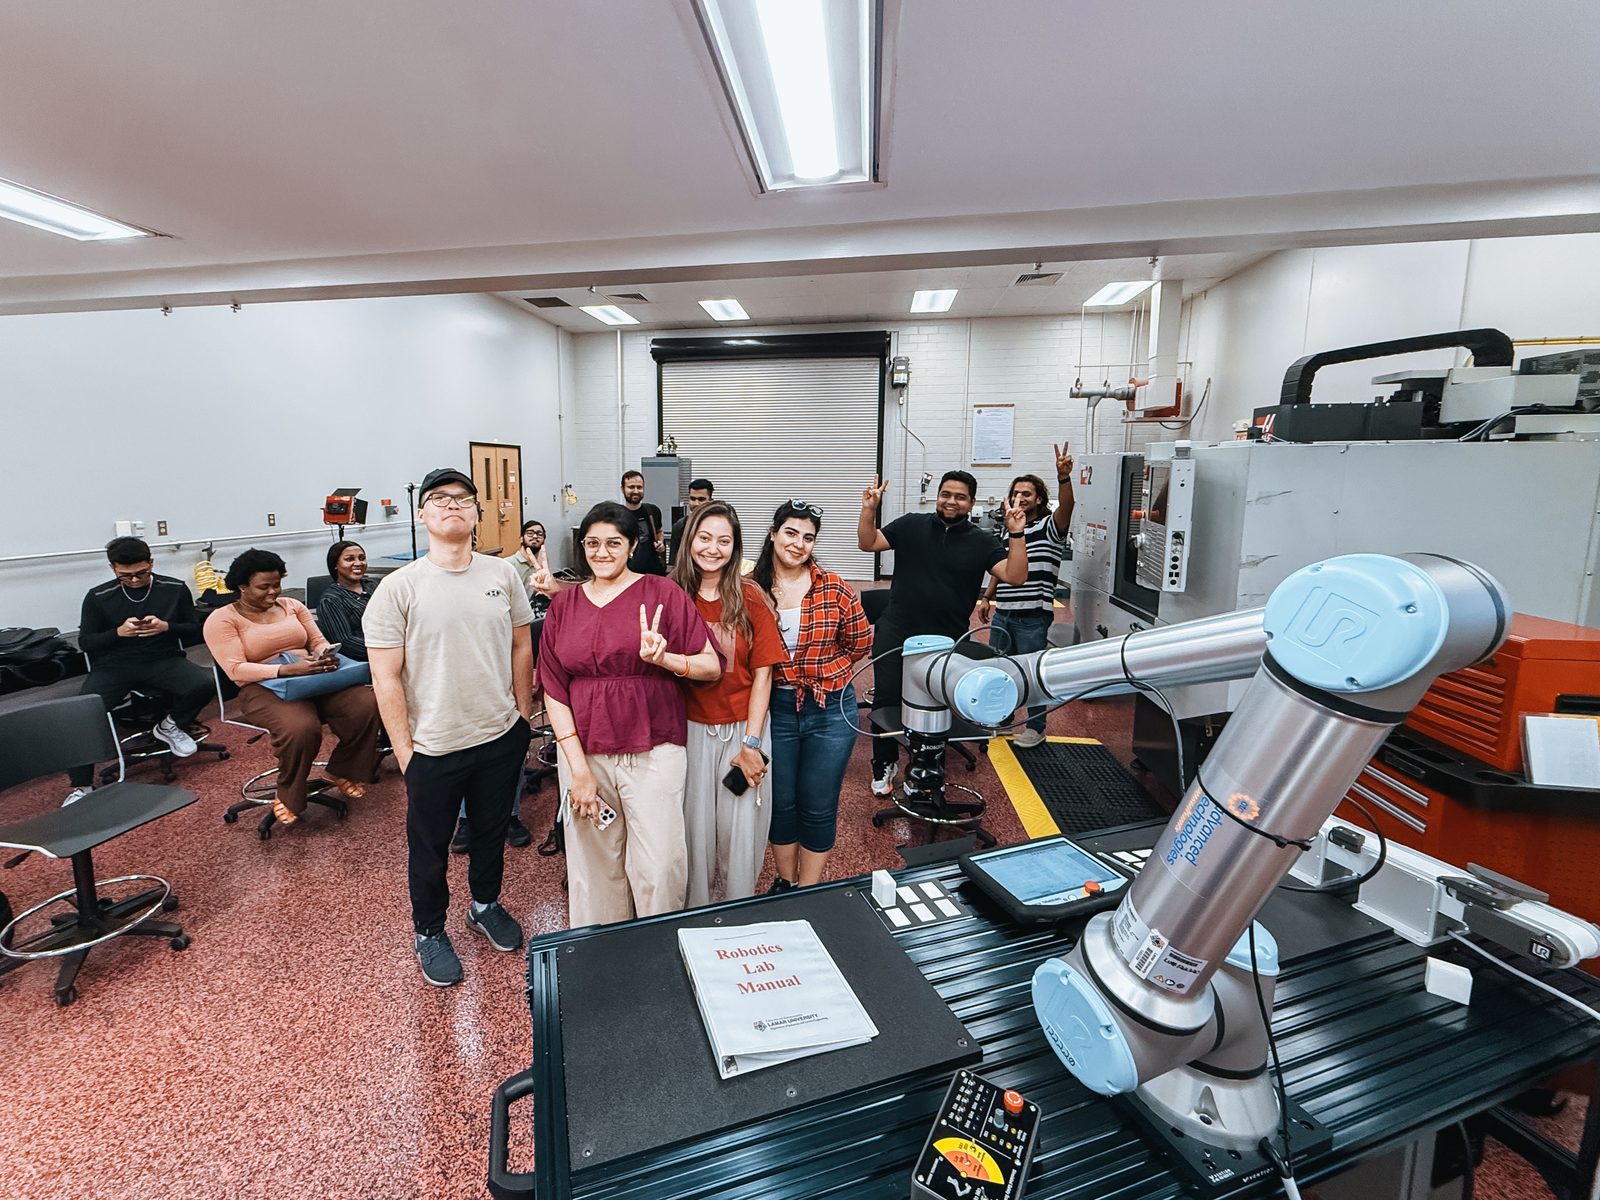
On Monday, September 28, 2026, students in INEN 6301: Advanced Robotics held their lab session in the renovated XRAI Lab. They worked through the UR10e Operations and Motion hands-on module and finished the session with a group competition.
The challenge
Each group programmed the UR10e with a Robotiq two-finger gripper to run the same task as fast as possible:
- Pick up the white cube.
- Carry it along a fixed route made of three straight segments and one semicircular arc.
- Place it at the target.
Groups were ranked by execution time, with errors recorded for each run.
The winners
Group 1 took first place with a run of 11.328 seconds and zero errors. Pictured in front of the robot, from left to right: Nhat Ton, Jyothi Supriya Chollangi, Ayesha Khatun, and Paniz Bioucki.
About the course
INEN 6301 is a doctoral-level course that pairs robotics theory with hands-on skill in collaborative robot operation and programming. Lectures cover kinematics, the Jacobian, dynamics and force control, and vision-guided manipulation. The lab sessions put the same ideas to work on a real UR10e. Students who complete the lab sessions earn the Educational Robotics Training – Core certification issued by Universal Robots.
The renovated XRAI Lab
This semester the renovated XRAI Lab is in regular use. The room holds 30+ students for robotics lab sessions and doubles as research space for lab members. A multi-camera system and a lighting system are installed for recording sessions and experiments.
The robot cell is built around a fully equipped Universal Robots UR10e, a six-axis collaborative arm with a 12.5 kg payload, 1300 mm reach, ±0.05 mm pose repeatability, and a force/torque sensor built into the tool flange. Around it we have:
- WINGMAN Cobot Tool Changer by TripleA Robotics
- Screwdriving system with a screw feeder
- Robotiq EPick vacuum gripper
- Robotiq two-finger gripper
- Conveyor
- Two SICK nanoScan3 Core safety laser scanners
- Multiple presence sensors
With this setup we can rebuild the kinds of multi-tool robot cells found in manufacturing and other industries: tool changes, fastening, material flow, and safety zones that react when people step in.
New to the UR10e? Start with the Getting Started with the UR10e Cobot guide, and see the rest of our equipment on the Lab page.